Manual TIG Welding and Robotic TIG Welding
This section has the following subsections:
TIG Welding Operation Weld Time
The formulas in this section are used by the Welding operation for both Manual TIG Welding and Robotic TIG Welding.
Weld Time = Arc Time + Tack Time
For each Weld GCD, weld time is the sum of the following:
-
Arc time (see formula)
-
Tack time (see formula)
Arc Time =
Arc Time Calculated + Gun Manipulation Time Arcing + Gun Clean Time Arcing
Arc time is the time for the arcing phase of welding—it excludes arc time for tack welding. Arc time is the sum of the following:
- Arc time calculated (see formula)
- Gun manipulation time arcing (see formula)
- Gun clean time arcing (see formula)
Arc Time Calculated
Arc time is the time for the arcing phase of welding—it excludes arc time for tack welding. Arc time is determined in one of two ways:
- Linear Rate Method: based on the following:
- Weld length
- Travel Speed
- Number of Welding Passes
- Volumetric Rate Method: based on the following:
- Weld Volume
- Deposition rate
See the formulas for Volume Method Arc Time and Length Method Arc Time Calculated, below.
Volume Method Arc Time Calculated =
(Theoretical Arc Time * Arc Time Standard) / Welding Efficiency Factor
Arc time is calculated using the volume method if the setup option Weld Cycle Time Method is set to Volumetric Rate Method (the default in starting point Digital Factories). In this case, arc time is the product of the following:
- Theoretical arc time (see formula)
- Arc time standard: multiplier to account for any operator pauses or breaks between cycles. Specified by the machine property Arc Time Std.
- Welding efficiency factor: factor to account for fixturing, clamping, moving, cooling, extinguishing, waiting, inspecting, and straightening that occurs during the act of welding. Specified by the cost model variable weldingEfficiencyFactor (0.45 in starting point Digital Factories).
Length Method Arc Time Calculated =
((Weld Length * Number of Weld Passes) / Travel Speed) /
Welding Efficiency Factor
Arc time is calculated using the length method if the setup option Weld Cycle Time Method is set to Linear Rate Method. In this case, arc time depends on the following:
- Weld length: imported from CAD or specified by the user.
- Number of Welding Passes
- Travel Speed
- Weld efficiency factor: accounts for time spent on activities such as fixturing and clamping, moving, waiting for cooling, inspecting, and straightening. The factor is specified by the cost model variable weldingEfficiencyFactor (0.45 in starting point Digital Factories).
Theoretical Arc time = GCD Volume / (Arc Efficiency * Deposition Rate)
Theoretical arc time depends on the following:
-
GCD volume (based on geometry extraction or user-specified weld dimensions and weld type; see Weld Volume)
-
Arc efficiency: fraction of welding wire that ends up in the weld and is not lost to spatter and evaporation. This value is specified by the cost model variable arcEfficency (0.86 in starting point Digital Factories).
-
Deposition rate (see formula)
Deposition rate = Pi * (Wire Diameter2 / 4 ) * Wire Feed Rate
Deposition rate is the weld volume per unit time that is deposited during the arcing phase. It depends on the following:
- Wire diameter: this is looked up in the lookup table tblTigWeldingV2 by the following:
- Weld Throat for a Canonical Weld that is equivalent to the portion of the weld created in a single pass. This is the throat for a Canonical Weld whose area equals the following: the Weld Cross-sectional Area of the current weld divided by the Number of Welding Passes.
- Assembly Material Type
- Wire feed rate is the wire length per unit time that is deposited during the arcing phase (specified by the machine property Wire Feed Rate)
Gun Manipulation Time Arcing =
Number of Welder Repositions * Gun Placement Time
Gun manipulation time during the arcing phase includes all tasks between arc welds such as lifting the hood or visor, moving to the next location, repositioning the torch, readying to strike, and so forth. It is the product of the following:
-
Number of welder repositions: for robotic processes, this is always 1. For manual welding, by default, this is specified by the formula below (Default Number of Welder Repositions). Users can override the default on a per-weld basis with the setup option Number of Welder Positions--see TIG Welding GCD-level Options.
-
Gun placement time (specified by the machine property Gun Placement Time)
Default Number of Welder Repositions =
Number of Weld Segments * Number of Repositions per Weld Segment
Default number of welder repositions is the product of the following:
-
Number of weld segments: specified by the geometric property # Segments.
-
Number of repositions per weld segment: see formula.
Number of Repositions per Weld Segment = rounup(
Weld Segment Length / Welder Reach)
Number of repositions per weld segment depends on the following:
-
Weld segment length: specified by the Weld GCD property Segment Length.
-
Welder reach: specified by the machine property Welder Reach.
Gun Clean Time = Arc Time * Gun Clean Time per Unit Arc Time
Gun clean time is the time for robotic cleaning of weld spatter from around the contact tip and nozzle. It is the product of the following:
-
Arc time (see formula)
-
Gun clean time per unit arc time (specified by the machine property Gun Clean Time per Arc)
Operation Tack Time Calculations
Tack Time =Tack Arc Time +
Tack Gun Manipulation Time + Tack Gun Clean Time
If tacking is enabled, tack time is the sum of the following:
-
Tack arc time (see formula)
-
Tack gun manipulation time (see formula)
-
Tack gun clean time (see formula)
If tacking is not enabled tack time is 0.
For robotic welding, by default in starting point Digital Factories, operators are assumed to perform tack welding in order to prepare the workpieces. Digital Factory Administrators can customize the default with the cost model variable enableTackingWithRoboticWelding. Users can override the default with the setup option Enable Tacking Operation.
For manual welding, tacking is always assumed to be performed.
Tack Arc Time = Theoretical Tack Arc Time * Arc Time Standard
Tack arc time is the product of the following:
-
Theoretical tack arc time (see formula)
-
Arc time standard: multiplier to account for any operator pauses or breaks between cycles. Specified by the machine property Arc Time Std.
Theoretical Tack Arc Time = Tack Volume / Arc Efficiency *
Deposition Rate
Theoretical tack arc time depends on the following:
-
Tack volume (see formula for appropriate weld type)
-
Arc efficiency: fraction of welding wire that ends up in the weld and is not lost to spatter and evaporation. This value is specified by the cost model variable arcEfficency (0.86 in starting point Digital Factories).
-
Deposition rate (see formula)
Tack Volume for Slot and Plug Welds =
gcd.volume * tackLength / tackPitch
The cost model assumes that the cross-section area of a tack weld is the same as the cross-section area of the robot-created weld—they differ only in length. For slot and plug welds, it assumes that the ratio of tack volume to the volume of the robot-created weld is the same as the ratio of tack length to tack pitch. (Tack pitch is the distance from the start of one tack weld to the start of the next tack weld.)
Tack volume for slot and plug welds depends on the following:
-
GCD volume (based on geometry extraction or user-specified weld dimensions and weld type; see Weld Volume)
-
Tack length (specified by the machine property Tack Length)
-
Tack pitch (specified by the machine property Tack Pitch)
Tack Volume for Non-slot, Non-plug Welds =
Tack Cross-section Area * tackLength * numTacks
Tack volume for welds other than slot and plug welds is the product of the following:
-
Tack cross-section area (see formula)
-
Tack length. This is the length of a single tack weld, specified by the machine property Tack Length.
-
Number of tacks (see formula)
Tack Cross-section Area = Weld Volume /
Weld Length * Number of Weld Segments
Tack cross-section area is the area of a tack weld cross-section normal to the weld’s length direction (the direction of motion of the gun during arcing). It depends on the following:
-
Weld volume
-
Weld length
-
Number of weld segments
Number of Tacks for Slot and Plug Welds= Number of Weld Segments
For slot and plug welds, the number of tacks is the same as the number of weld segments specified by the user or determined by geometry extraction.
Number of Tacks for Non-slot, Non-plug Welds =
Roundup(Arcing Length / Tack Pitch )
For non-slot, non-plug welds, the number of tacks is the minimum number of tack welds required to have a tack weld at the beginning and end of the weld GCD, with tack welds in between spaced by no more than tack pitch. Number of tacks is the quotient of the following, rounded up the nearest whole number:
-
Arcing length (see formula)
-
Tack pitch (specified by the machine property Tack Pitch)
Arcing Length = Segment Length * Number of Segments
Arcing length is the total distance the point of deposition travels during arcing phase for all weld segments. It is the product of the following:
-
Segment length (specified by the user or determined by geometry extraction)
-
Number of segments (specified by the user or determined by geometry extraction)
Tack Gun Manipulation Time = Number of Tacks * Gun Placement Time per Segment
For tacking, gun manipulation time is the product of the following:
-
Number of tacks (see formula)
-
Gun placement time per segment (specified by the machine property Gun Placement Time)
Tack Gun Clean Time = Tack Arc Time * Gun Clean Time per Unit Arc Time
Gun clean time is the time for robotic cleaning of weld spatter from around the contact tip and nozzle. The gun cleaning time associated with tacking is the product of the following:
-
Tack arc time (see formula)
-
Gun clean time per unit arc time (specified by the machine property Gun Clean Time per Arc)
TIG Welding Weld Weight
The formula in this section is used by both Manual and Robotic TIG Welding.
Weld Weight = GCD Volume * Weld Density
The weight of each weld GCD is used to calculate the total weld weight, which affects expendable tooling costs, as well as total assembly weight, which affects Pick and Place costs. The weight in kilograms of each weld GCD is the product of the following:
-
GCD Volume (based on geometry extraction or user-specified weld dimensions and weld type; see Weld Volume)
-
Weld density: specified in kg/m3 by the machine property Weld Density. aPriori converts this value to kg/mm3.
Manual TIG Welding Accounting Calculations
Amortized Batch Setup = (Setup Time * (Labor Rate + Direct Overhead Rate)) / Batch Size
Amortized batch setup depends on the following:
-
Setup time (specified as the machine property Setup Time)
-
Labor rate: this is the product of the following:
- Machine property Labor Rate
- Cost model variable laborRateAdjustmentFactor (1 in starting point Digital Factories)
- Machine property Work Center Labor Rate Factor (1 in starting point Digital Factories)
-
Direct overhead rate (see Direct and Indirect Overhead)
-
Batch size (specified in the Production Scenario screen of the Cost Guide)
Labor Cost = Labor Time * Labor Rate / Final Yield
Labor cost depends on the following:
-
Labor time (see formula)
-
Labor rate: this is the product of the following:
- Machine property Labor Rate
- Cost model variable laborRateAdjustmentFactor (1 in starting point Digital Factories)
- Machine property Work Center Labor Rate Factor (1 in starting point Digital Factories)
-
Final yield (see Yields)
Labor Time = (Operation Weld Times + Reorientation Time) * Labor Time Standard
Labor time is the product of the following:
-
Operation weld times: sum of the weld times and tack times of all child operations; see TIG Welding Operation Weld Time.
-
Reorientation time: product of the following:
-
Time per reorientation: if reorientation is fully automated, this is specified by the cost model variable defaultAutomatedReorientationTime (30 seconds in starting point Digital Factories). Otherwise, time per reorientation is looked up by assembly weight and largest dimension in the lookup table componentLoadTime.
-
-
Labor time standard: specified as the machine property Labor Time Standard. This multiplier is used to account for otherwise unaccounted for factors that affect labor time, such as operator fatigue or time spent by the operator for cleaning or maintenance.
Note: Labor time is independent of the number of operators, and cycle time is inversely proportional to the number of operators; see Manual TIG Welding Process Cycle Time.
Manual TIG Welding Process Cycle Time
Cycle Time = (Labor Time / Number of Operators)
* Cycle Time Adjustment Factor
Cycle time depends on the following:
-
Labor Time (see Manual TIG Welding Accounting Calculations)
-
Number of operators: specified by the machine property Number of Operators. Note that cycle time is inversely proportional to the number of operators. Increasing the number of operators is assumed to speed up the welding cycle.
-
Cycle time adjustment factor: specified by the cost model variable cycleTimeAdjustmentFactor; 1 in aPriori starting point Digital Factories. If you want to model an unbalanced, push assembly line, set cycleTimeAdjustmentFactor to a value greater than 1 in order to account for the cost of extra buffer capacity.
Note: Indirect overhead depends on cycle time, while direct overhead depends on labor time. Cycle time contributes to part cost only via indirect overhead.
Robotic TIG Welding Labor Time
During the time the robot is welding one assembly, the operator (or operators or fraction of an operator) who tends the robotic welding machine is assumed to perform both the following tasks on the subsequent assembly:
-
Pick and place (P&P in the diagram below)
-
Manual tack welding (Tack in the diagram below)

Elapsed Time = max (Pick And Place Labor Time +
Operation Tack Times / Number of Operators, Operation Weld Times /
Number of Weld Heads)
Elapsed time for robotic welding is calculated based on two cases:
-
If tacking is completed before the robot finishes welding, elapsed time for this process is the elapsed time for the robot-performed welding (sum of the weld times on the child GCDs divided by the number of weld heads).
-
If tacking is completed after the robot finishes welding, elapsed time for this process is pick and place process time plus the elapsed time for tacking (sum of the tack times on the child GCDs divided by the number of operators).
Therefore, elapsed time depends on the following:
-
Pick and place labor time (see Pick and Place Accounting Calculations)
-
Operation tack times (sum of the tack times for all child operations--see Tack Time formula in TIG Welding Operation Weld Time)
-
Number of operators: specified by the machine property Number of Operators or by the PSO Number of operators tending to this machine. This is the number of operators tending to the robotic welding machine, some or all of whom also do pick and place tasks.
-
Operation weld times (sum of the weld times for all child operations--see Weld Time formula in TIG Welding Operation Weld Time)
-
Number of weld heads (specified by the machine property Number of Weld Heads)
Note: The cost model assumes that elapsed tack time is inversely proportional to the number of operators, and elapsed robot-performed weld time is inversely proportional to the number of weld heads.
Labor Time = (Elpased Time * Number of Operators *
Labor Time standard) – Pick And Place Labor Time
Labor time for robotic TIG welding is the labor time for a robotic TIG welding cycle that is over and above the time spent on pick and place. In other words, the labor time for robotic TIG welding is the difference between the following:
-
Elapsed time (see below) for robotic TIG welding multiplied by the number of operators (and adjusted by labor time standard)
-
Labor time for one pick and place cycle
Therefore, labor time depends on the following:
-
Elapsed time (see formula)
-
Number of operators: specified by the machine property Number of Operators or by the PSO Number of operators tending to this machine. This is the number of operators tending to the robotic welding machine, some or all of whom also do pick and place tasks.
The corresponding Pick and Place machine property or PSO (see Process Cycle Time Calculation and Pick and Place Options) specifies the total number of operators performing pick and place tasks, including any Robotic TIG Welding operators who perform pick and place tasks; see Number of Operators for more information.
-
Labor time standard: specified as the machine property Labor Time Standard. This multiplier is used to account for otherwise unaccounted for factors that affect labor time, such as operator fatigue or time spent by the operator for cleaning or maintenance.
-
Pick and place labor time (see Pick and Place Accounting Calculations)
Robotic TIG Welding Accounting Calculations
Amortized Batch Setup = (Setup Time *
(Labor Rate + Direct Overhead Rate)) / Batch Size
Amortized batch setup depends on the following:
-
Setup time (specified as the machine property Setup Time)
-
Labor rate: this is the product of the following:
- Machine property Labor Rate
- Cost model variable laborRateAdjustmentFactor (1 in starting point Digital Factories)
- Machine property Work Center Labor Rate Factor (1 in starting point Digital Factories)
-
Direct overhead rate (see Direct and Indirect Overhead)
-
Batch size (specified in the Production Scenario screen of the Cost Guide)
Labor Cost = Labor Time * Labor Rate / Final Yield
Labor cost depends on the following:
-
Labor time (see Robotic TIG Welding Labor Time)
-
Labor rate: this is the product of the following:
- Machine property Labor Rate
- Cost model variable laborRateAdjustmentFactor (1 in starting point Digital Factories)
- Machine property Work Center Labor Rate Factor (1 in starting point Digital Factories)
-
Final yield (see Yields)
TIG Welding Expendable Tooling Calculation
The formulas in this section are used by both Manual and Robotic TIG Welding.
Expendable Tooling Cost = ((Weld Weight * Wire Cost) +
Antispatter Spray Cost + Nozzle Cost + Tip Cost) /
Final Yield
Expendable tooling cost accounts for the cost of the welding wire for the assembly. It depends on the following:
-
Weld weight (see TIG Welding Weld Weight)
-
Wire cost (specified by the machine property Wire Cost)
-
Antispatter spray cost: cost per unit mass for antispatter spray. This is the sum of the spray costs for all the assembly's welds. By default in starting point Digital Factories, the cost for a given weld is specified by the formula Antispatter Spray Cost (see below). Administrators can customize the default, and specify no cost for antisplatter spray, by setting the cost model variable weldAntiSpatterSprayEnabled to false. Users can override the default on a per weld basis with the setup option Enable Anti-Spatter Spray.
-
Nozzle cost (see formula)
-
Tip cost (see formula)
-
Final yield (see Yields)
Antispatter Spray Cost =
Antispatter Spray Mass Applied *
Antispatter Spray Cost Per Unit Mass
This is the cost of antispatter spray for a given weld, provided that the setup option Enable Anti-Spatter Spray is set to true (the cost is 0 otherwise). It depends on the following:
-
Antispatter spray mass applied (see formula)
-
Antispatter Spray Cost Per Unit Mass
Antispatter Spray Cost Per Unit Mass =
(Spray Cost / (Spray Volume * Spray Density))
This is the cost per unit mass of antispatter spray for a given weld. It depends on the following:
-
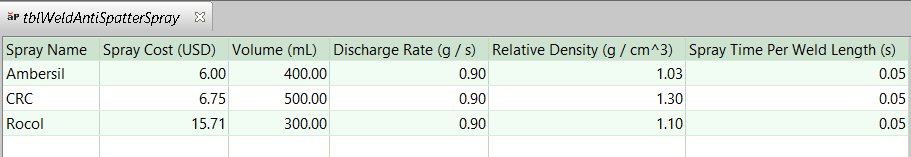
Spray cost: this is the Spray Cost of the lowest-Spray-Cost spray listed in the lookup table tblWeldAntiSpatterSpray. (Note that Spray Cost is not cost per unit mass or unit volume, but rather is cost per container.)

-
Spray volume: this is the Volume of one container of spray for the lowest-Spray-Cost spray listed in the lookup table tblWeldAntiSpatterSpray.
-
Spray density: this is the Density of the lowest-Spray-Cost spray listed in the lookup table tblWeldAntiSpatterSpray.
Antispatter Spray Mass Applied =
((Weld Length * Spray Time Per Weld Length) * Spray Discharge Rate)
The mass of the antispatter spray applied to a given weld depends on the following:
-
Weld length: specified by the user or imported from CAD.
-
Spray time per weld length: this is the time per unit length to apply the spray. It is the Spray Time Per Weld Length for the lowest-Spray-Cost spray listed in the lookup table tblWeldAntiSpatterSpray.
-
Spray discharge rate: this is the mass per unit time that is expended during spraying.
Nozzle Cost = (Weld Weight /
Weld Nozzle Replacement Rate) * Weld Nozzle Cost
Nozzle cost depends on the following:
-
Weld weight: total weld weight for all the assembly's welds--see TIG Welding Weld Weight.
-
Weld nozzle replacement rate: the mass of welding wire used per nozzle, specified by the cost model variable weldNozzleReplacementRate—18kg in starting point Digital Factories.
-
Weld nozzle cost: cost per nozzle, specified by the cost model variable weldNozzleCost—13.57 U.S. dollars per nozzle in starting point Digital Factories.
Tip Cost = (Weld Weight /
Weld Tip Replacement Rate) * Weld Tip Cost
Nozzle cost depends on the following:
-
Weld weight: total weld weight for all the assembly's welds--see TIG Welding Weld Weight.
-
Weld tip replacement rate: the mass of welding wire used per nozzle, specified by the cost model variable weldTipReplacementRate—9kg in starting point Digital Factories.
-
Weld nozzle cost: cost per nozzle, specified by the cost model variable weldTipCost—0.32 U.S. dollars per nozzle in starting point Digital Factories.
Additional Direct Costs for TIG Welding
Additional direct costs consist of the sum of the gas costs for all the assembly's welds:
Gas Cost = Weld Time * Gas Cost Per Hour
Gas cost is the product of the following:
-
Weld time: this is the sum of all the operation-level weld times--see TIG Welding Operation Weld Time).
-
Gas cost per hour: this is looked up by Assembly Material Type, Travel Speed, and Gas Type used for Welding in the lookup table tblTigWelding.
Note: Weld time is converted to hours in this formula, since gas cost is per hour.
Programming Cost for Robotic TIG Welding
Programming cost is the product of the machine Labor Rate and the total programming time. Programming time per weld is specified by the machine property Programming Time per Weld (300 seconds in starting point Digital Factories).